Couple a primary to a secondary and the resonance splits in two. The driver runs on one of the two, and which one decides most of what the coil does. The frequency you measured on the secondary alone is no longer a mode of the coupled coil.
Where the two come from
The resonance condition for the coupled system is
(1 - w1^2/w^2)(1 - w2^2/w^2) = k^2and solving it for w gives
w±^2 =
  [ w1^2 + w2^2
    ± sqrt( (w1^2-w2^2)^2
            + 4k^2 w1^2 w2^2 ) ]
  / [ 2(1 - k^2) ]
When the two are tuned to each other, that reduces to the familiar form:
f± = f0 / sqrt(1 -+ k)Tighter coupling pushes the two further apart. Here it is worked on the QCW we keep our figures for (primary 349.9 kHz, secondary 426.49, both from JavaTC), using the general form above rather than the tuned one, because that machine is deliberately detuned:
k      lower  upper  apart
0.30   328.9  475.7  146.8
0.39   320.0  506.5  186.5
0.421  317.0  519.1  202.1  <-
0.45   314.2  531.9  217.7
0.50   309.5  556.8  247.3

<- as built
Ours is the marked row. The path the two poles then follow as the arc grows is on its own page.
The familiar form still works on a detuned machine, but only if you read its f0 as the primary's own resonance and not the secondary's. Using the secondary looks almost right and is wrong. loneoceans publishes a primary alone at 328.4 kHz and a measured upper pole at 420.2. Inverted, those two give k = 0.389 against the 0.38 he states; run forwards they give 417.1 against the 420.2 he measured. Coupled poles runs the forward direction on a primary and a secondary tuned apart rather than together, and the inversion from a full sweep, both dips and the peak between them. Start from that coil's secondary, 339.3, and the same arithmetic misses by enough to tempt you into an explanation that is not there. Two further coils fit the same way, and on both the route through the secondary is several per cent out. We do not quote how closely those two agree, because the pairs we can check are davekni's at 0.17 per cent and MS.Lab's at 0.8, and claiming a tighter figure than either would mean naming the coil and linking it.
When the two are tuned to each other, the gap between the poles depends only on k, and at these couplings it is large: 15 per cent of f0 at a DRSSTC's 0.15, 52 per cent at a QCW's 0.45, and 109 at the 0.71 of the coil checked further down, where the two poles end up further apart than the frequency they came from. That is our arithmetic on the form above, not anyone's measurement.
Not every coupled pair shows two peaks, whatever the opening sentence suggests. Below a certain coupling there is one peak, and splitting is what running above it looks like. A 1991 article arguing that the coils of its day were overcoupled reports the same thing with the value judgement reversed: at k = 0.25 it sees "dual resonant peaks with broad skirts", and at critical coupling one sharp peak. Its complaints are the failure modes we list too, beating and sputtering output and a secondary destroyed by arcing along itself, and its remedy is to come back down towards critical. The physics has not changed since, but the answer has. A slow ramp lets the arc form and clamp the secondary's voltage, which makes the overcoupled regime workable and lets k go up instead of down. That article is about spark-gap coils and does not name its author. Comparing its regime with a QCW's, and the conclusion drawn from that, are ours.
What two poles look like on a scope, before any arc:
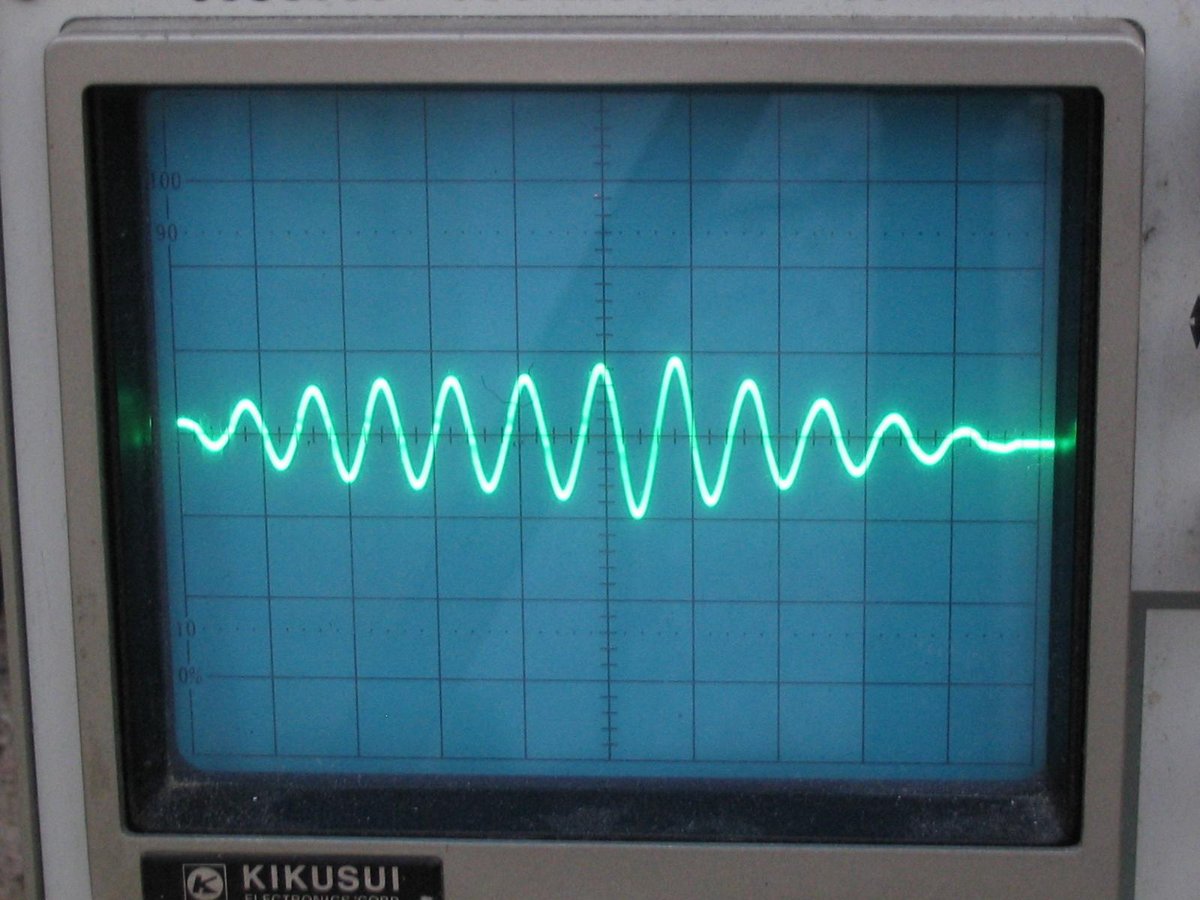
Which one you land on
davekni and Uspring arrived at the same rule independently. With the primary tuned below the secondary, the driver settles on the lower pole. With the primary above, it settles on the upper.
Applied to the loaded coil, not the bare one
The rule is right, but it is easy to apply to the wrong state of the coil. One published build looks at first like a flat contradiction of it. On loneoceans' first QCW an ordinary UD2.7, no PLL and no self-oscillation, runs with the primary tapped at turn 7.5, 392 kHz, and he reports that the coil oscillates itself to the upper pole. Every figure below is his, from that page: the primary alone at turn 7.5, the secondary alone with its single toroid, the secondary with a metre of wire on it standing in for a streamer, and k = 0.32.
Work it in both states and the contradiction goes away.
primary tapped at 392, k = 0.32

no arc, secondary 408
  lower 44 below
  upper 94 above  -> lower

1 m streamer, secondary 310
  lower 100 below
  upper 47 above  -> upper
With no arc out the primary is nearer the lower pole, and with the arc loading the secondary it is nearer the upper. His coil settles where the rule says once the arc is out, which is the state that matters. The mistake is applying the rule to a bare coil.
And the criterion is the midpoint, not the loaded secondary
This tightens a rule we had been using in a weaker form. "Primary above the loaded secondary" is necessary but not sufficient. What decides which pole the primary is nearer is the midpoint between the two poles, and because coupling is not symmetric about the secondary, those are different tests.
On the coil we keep our figures for:
arc    midpoint   primary 349.9
1.5 m    379.5    30 below
2.0 m    370.4    20 below
2.81     358.1     8 below
3.46     349.9    level
The primary only reaches the midpoint at 3.46 m, and the pole structure comes apart at or before 2.81. On this machine the upper pole is therefore never the nearer one at any arc length it can reach, and the forcing is needed for the whole ramp, not just until the arc grows enough to take over. Anders' criterion is met from about 1.65 m onward, and that is not enough.
And the mechanism underneath both is gain
The proximity rule describes the outcome but not the cause, and the cause matters because it is what a modification has to overcome. Anders Mikkelsen states it directly:
[a self-oscillating UD2.7 and similar driver] would need more gain at the upper pole, which means that the primary needs to be tuned above the loaded secondary frequency. This is not possible for a plain self-oscillating driver, as the lower pole would have more gain without spark detuning.
He puts the excess the upper pole needs at "maybe 6 dB?".
You can check that on a coil with known numbers by working out the primary current each pole would draw at the same bridge voltage:
arc    lower is stronger by
0                +5.5 dB
0.5 m            +9.4 dB
1.0 m            +5.5 dB
1.5 m            +1.9 dB
1.8 m            crossover
2.0 m            -1.0 dB
The crossover at about 1.8 m lands in the same place as Anders' tuning criterion, by a different route. His condition, primary above the loaded secondary, is met between 1.65 and 2.0 m on this coil, since the primary sits at 349.9 against a loaded secondary of 355.1 at 1.5 m and 338.2 at 2.0. One calculation goes through currents and the other through tuning, and they land on the same point.
A model published independently on kechuang puts the same turnover at a primary tuned to 0.91 of the secondary: below that its lower pole draws the stronger current, above it the upper does. We cannot link it, because kechuang answers a fetch from here with a captcha gate, and the thread was read before that started. Its crossover ratio is on their circuit and their numbers, so it cannot be set beside the 1.8 m directly, but the sign and its direction agree, which gives a third route to the same result.
Across the useful part of a ramp, then, the lower pole holds an advantage of roughly 2 to 9 dB, while the upper one needs a 6 dB excess to be chosen. The total deficit is 8 to 15 dB. Feedback left to itself therefore goes to the lower pole every time, not just some of the time. What that deficit means for a driver that starts from noise, and how a modification can beat it anyway, is covered with the modification.
One figure from that subject belongs here, because the deficit above has to be measured against it. An injection-locked driver holds the upper pole through 14 dB of excess gain at the lower one and loses it at 20, a limit stated in gain terms in HVF 3140. Whether that covers the 8 to 15 dB above depends on a definition no one has stated. The 8 to 15 is a sum: the lower pole's own 2 to 9 dB advantage, plus the 6 dB the upper needs before a driver will choose it. His 14 is the excess gain at the lower pole. Read against the sum, the lock covers the ramp with nothing to spare, with the deepest part of the deficit at the edge of what it will hold. Read against the advantage alone, 2 to 9 against 14, it has room to spare. The source does not say which quantity his figure is measured against, so we assert neither. This is also why the line falls where it does between boards. An unmodified UD2.7 needs its primary at or above the loaded secondary, the second of the three strategies below, while a PLL-locked board can be tuned further down than that and still be held on the upper pole.
So there are three strategies, not two
- Primary below the loaded secondary, upper pole forced. The detuning rule is met and the driver has to be modified. davekni calls this the ideal and says plainly that it requires either a PLL or self-oscillation.
- Primary above the loaded secondary. The upper pole comes for free, with no starting oscillator and no PLL, and the detuning rule is given up to get it. loneoceans sits 15.0 per cent above his loaded secondary, taking the load as about a metre of arc [derived from his own two figures: a primary alone at 328.4 kHz against a secondary reading 285.6 with a metre of wire to the table, which is his stand-in for arc loading].
- Lower pole, unmodified. An ordinary DRSSTC lives happily here, and a QCW loses the linear ramp it exists for.
We used to list the first and the third and treat the second as a mistake. It is a trade of pole for tuning, and which one is right depends on whether you would rather modify a driver or give up matching under the arc's load.
The first of the three is the common one, though "the ideal, requiring a PLL or self-oscillation" makes it sound like a fringe position:
builder      primary vs secondary
Lucasww       244 < 300
CJ            395-420 < 430-450
ours          349.9 < 426.5
Lucasww draws 1.30 m on a UD2.9 in pulse-skip mode; CJ draws 2.39 m and is the only one of the three with both frequencies measured rather than computed. All three have the primary below the loaded secondary and run on the upper pole, so this is the configuration builders actually end up in.
Lucasww does not state his primary frequency. It is implied, because the triplet he does give (300 kHz, k = 0.44, an upper pole of 370) only closes with a primary at 244, so treat it as inferred rather than reported.
Two external checks of the pole equation
The first is the sharper one, because none of it comes from a description. davekni's oversized QCW in HVF 2397 is specified by component values, and he states the pole he measured.
primary   5.6 uH · 64.8 nF
            -> 264.2 kHz
secondary 11.8 mH · 32 pF
            -> 259.0 kHz
k = 0.71

full coupled pair, both
resonances in
         -> upper 485.8
         -> lower 200.0
he measured    485
             +0.17 %
Here the familiar equation is the wrong one. His two circuits are not at the same frequency, so f/√(1-k) does not apply: it assumes they are, and fed his secondary alone it returns 481.0 while his primary alone returns 490.6 [derived]. The form used above is the full coupled pair, f²± = [f₁²+f₂² ± √((f₁²-f₂²)² + 4k²f₁²f₂²)] / [2(1-k²)], which takes both resonances and returns one answer. It reproduces both of his poles, 485.8 against the 485 he measured and 200.0 below, and there is no need to decide which circuit is the natural frequency because the equation is given both.
On this coil the two routes would not have separated. Feed the simple form the geometric mean of his two resonances and it returns 485.8 and 200.0 as well, because his circuits sit two per cent apart and at that spacing the two agree. The full form is still the one to use, because it keeps working when the circuits are far apart. On our coil, 349.9 against 426.5, the same two routes land 2.2 per cent apart on both poles, 317.0 and 519.1 against 324.1 and 507.7 [derived]. His case is one where the choice does not show.
That takes you from parts to a measured frequency with nothing adjusted in between, at k = 0.71. That is twice as tight as our coil, so the equation is not just fitted to one case. It also puts his lower pole at 200.0 kHz. At that coupling the two poles are a factor of 2.43 apart, the QCW habit of tight coupling taken further than on any other coil here.
It also works backwards, and backwards it gives a number no one published. Take his k = 0.71 and the 485 he measured, invert the familiar form, and the natural frequency under the pair comes out at 261.2 kHz, against the 259.0 his inductance and capacitance give in the block above. That is 0.84 per cent, from two routes that share no input. There is a limit too. He holds primary and secondary at about the same 260 kHz, so his coil cannot tell the two circuits apart as inputs. That limits what his case tests, not what the equation needs, since the full form takes both and does not ask which is which.
And one against a coil described rather than specified
MS.Lab publishes enough for a check: primary 313 kHz, k = 0.5, and a working frequency reported as 480 to 490 kHz. We do not link those three anywhere, because the page they were read on has not been found again. Treat the check below as reported rather than citable. It is the only one of the three here whose inputs a reader cannot go and look at.
secondary measured in place
  356 -> upper 476.0   -0.8 %

secondary measured on a bench
  411 -> upper 525.2   +9.4 %
This one agrees to within a per cent, but only with the secondary measured where the coil actually stands. The number that goes into this equation has to be the resonance in situ, not the bench figure, and here the two differ by 55 kHz.
Two more things from that build. Flashovers that looked like racing sparks turned out to be barrier discharges between primary and secondary, and potting cured them, which is an easy fault to misdiagnose. The ramp shape he settled on was the plain one, which independently supports the ordering we already give.
Which one a ramped coil can actually use
Everything above holds for any coupled pair. This section only applies to a machine with a ramp, and the ramp is why the choice matters: the frequency slides the whole way down, so the real question is which pole is still doing the job at the end.
Coupling splits the resonance in two and the driver holds one of them for the whole ramp. The choice is usually framed as a preference, and framed that way the lower pole wins most of the comparison. On this machine only one pole still does the job at the end, and it is not the one the coil goes to by itself.
Start with where the driver lands if nothing stops it. With plain feedback off the primary's current zero, it settles on the pole nearest the primary's own frequency, and the primary is at 349.9:
distance from the primary's 349.9
           to lower  to upper  lands
no arc         32.9     169.2  lower
1.5 m arc      54.2     113.4  lower
That holds at both ends of the ramp, by a wide margin. Without forcing the upper pole the machine runs in the mode it was not built for, and the starting oscillator or PLL is there to prevent that. Which changes to make to an ordinary board, in the words of the people who made them, is converting a DRSSTC driver.
Clearing Anders' criterion is not enough either. As worked out above, the primary on this coil only reaches the midpoint between the poles at 3.46 m, while the pole structure comes apart at or before 2.81, so the forcing is needed for the whole ramp. The third strategy, putting the primary above the loaded secondary and giving up the tuning rule instead, avoids all of this.
This explains a line of davekni's that can read like a shrug: the ideal is to run at upper pole while primary is tuned below secondary, and that ideal requires either a PLL or self-oscillation. On a QCW, detuning and the driver modification are not two independent decisions. Detuning makes the modification compulsory. The gain argument is set out above; the conflict between the two rules is our own reading, and it is arithmetic rather than modelling: the primary is below the loaded secondary at every arc length short of the design point, which is what the rule asks for.
Then there is why it matters. The first reason has nothing to do with frequency. The lower pole breaks the ramp, and the ramp is what a QCW is for:
Anders Mikkelsen: Lower pole operation leads to the tank drawing more power as the secondary gets additional capacitive loading from the arc, making it hard to slowly ramp the power up. Most people prefer to run QCWs on the upper pole as it gives a more linear response of power vs bridge voltage.
A QCW exists to raise power smoothly and predictably. On a pole where power rises by itself as the arc grows, it cannot do that at all. An ordinary DRSSTC does not care, because it has no ramp, so the lower pole is ordinary there and wrong here.
The conclusion is firm but the mechanism is not. Our own arithmetic at a fixed bus gives negative feedback on both poles (reflected resistance rises through the ramp and the current holds itself back), but the self-limiting is about 3.7 times weaker on the lower one. Anders describes a runaway; we get a slack brake. The signs are opposite and the conclusion is the same, and the practical difference is real: a runaway cannot be compensated in advance, while a slack brake can if you know its law. He has built the coils and we have a model with one calibrated constant, so doubt the model first.
The sword band gives the same answer. Straight swords need 300 kHz and up, which is Anders' threshold, and the lower pole leaves that band almost at once:
arc     sec   lower   upper
0     426.5   317.0   519.1
1.0   374.8   302.9   477.2
1.2   366.1   299.9   471.0  band
1.5   355.1   295.7   463.3
2.0   338.2   288.4   452.4

band = lower leaves 300 kHz
The lower pole is out of the band at about 1.2 metres. The upper one never leaves it, however far the arc gets. Grow the arc without limit and the loaded secondary goes to zero, at which point the upper pole is f_pri/√(1-k²), 385.8 kHz here [derived, 349.9 / √(1 - 0.421²)]. That is a floor, and it sits above the threshold. No arc length takes the upper pole out of the band, so none is quoted, and there is no need to stretch the arc capacitance to find one.
Treat that 1.2 m as a soft mark whose error runs downwards. It comes from one coil's arc capacitance, 4.14 pF per metre, which is our own calibration rather than a measurement. The two published measurements that hold up both sit above it, Anders at 5.03 and Weston's three-foot capture at 7.66. The mark goes as one over the capacitance, so either of them shortens it, to 0.99 m and to 0.65 [derived]. Take 1.2 as a ceiling, not a middle. The spread and the withdrawal behind it are on one page. The main result does not move: at every capacitance in that range the lower pole is out of the band before 1.5 m, and the upper one never leaves it. Only the decimal place is uncertain.
The two poles do not sink the same way, and the difference is not the one we used to claim. Differentiate the pole equation along the ramp and the lower track falls at a near-constant rate the whole way: 13.4 kHz per metre at the start, 14.6 at its steepest around 1.5 m, 13.7 by three metres. It never accelerates. The upper one is the one that changes. It starts at 54.7 kHz per metre and is down to 12.4 by three metres, slowing by a factor of four. The two rates only meet at 2.73 m.
An earlier version said the lower pole "starts falling fast" past 1.65 m, where the secondary crosses the primary. That was wrong. 1.65 m is where the two natural frequencies cross, and it is a real point: it is where the detuning rule is exactly met. It is not where the modes trade character. At k = 0.421 the coupling is strong enough to smear that handover across metres instead of snapping it at the crossing, and the arithmetic puts the crossover at 2.73 m. That is almost certainly further than the machine goes. The pole structure comes apart at or before 2.81 m, sooner given a large split, so the handover probably never happens inside a real bang at all.
The lower pole's smaller percentage fall is not much consolation. It holds its slower rate all the way, but it starts from a point already below the useful band. What you have over the ramp is the frequency you are at, however little it moved.
The lower pole does have real advantages, and not only efficiency. It reaches its own pole unaided, it drifts less with a spread in coupling, and it is easier on the hardware: copper loss follows skin depth and goes as the square root of frequency, and the gate supply's average current goes as Q_g·f. With no arc that is 1.28 times less copper loss and 1.64 times less gate current; under a 1.5 m arc, 1.25 and 1.57. If heat ever shows up as a point against the lower pole, the sign has been flipped.
The upper pole has one numerical advantage of its own: 12 dB more power into the arc in davekni's simulation. Twelve decibels of power is a factor of 16, not the factor of four we used to print. Four is what you get by applying the amplitude form, 10^(dB/20), to a quantity that was stated as power.
The sentence it came from carries a condition that matters more than the factor: "for this simulated load and constant bridge voltage". One load, one simulation, one operating point. It is evidence that the upper pole matters a lot, not a coefficient to multiply anything by, and a tidy 16× invites exactly that.
Count them up. For the lower pole: it reaches itself unaided, it drifts less with a spread in coupling, it moves a smaller fraction across the ramp, and it costs less in copper and in gate current. That is five. For the upper: the ramp stays linear, the band stays above the sword threshold, and the arc gets more power. That is three. The upper still wins, because two of its three decide whether the machine does its job at all. Efficiency in a mode that will not ramp, and that makes a branching discharge instead of a sword, is no use to you.
All of this applies to the start and the middle of the ramp. Past a certain loading the pole structure itself comes apart: the centre frequency and one pole go away and a single working frequency is left, near the primary's resonance, which on this coil is 349.9 kHz and so still above the sword threshold. At that point there is no pole to choose. The condition, and why it may arrive sooner than it sounds, are further down.
The trap
The secondary frequency you measured is the resonance with the primary taken away. In the assembled system there is no such mode.
Our machine shows it without a hypothetical: 426.49 kHz is what the secondary measures on its own, and with the primary beside it the working points with no arc out are 317.0 and 519.1. Neither is 426.5, and nothing in the assembled coil is.
Put a starting oscillator on the pole you are aiming at, not on the secondary's frequency. Where exactly, and why slightly above rather than on it, is covered with the driver.
One asymmetry that is not about power
The lower pole is where the system lands unaided and it is easier on everything, but it carries a higher flashover risk when the windings come together. On the upper pole the secondary's field is lower inside the winding, so the usual advice that tight coupling is survivable holds there and not on the lower.
Tuned exactly together you get beating, and the primary current visibly breathes. That is what two close poles do, and it is not a tuning fault.
What a room full of builders does with this, on a different forum
Builders elsewhere have reached the same conclusions without setting out to. On hvdiy in 2016 a builder posted a method for measuring the secondary's frequency: hold a scope probe in the air near the running coil, not close enough to be struck, and if the trace is a sine then "然后示波器显示的频率就是TC次级的频率了", the frequency the scope shows is the TC's secondary frequency. No current transformer, no ring, just a probe and the coil (hvdiy 34298).
Two people objected within ten minutes, and between them they raised both main points of the argument above.
The first asked what happens when the two are far apart: "如果初级的频率和次级的频率相差较大,不在次级的通频带之内,这种方法是否可行?", if the primary's frequency and the secondary's differ a lot, outside the secondary's passband, is the method still viable? The author answered with a measurement: "我初级给的频率是200多k,次级输出460k", his primary is driven at two hundred and something kilohertz and the secondary reads 460. A factor of more than two is not a pole pair. Whatever that probe was hearing, it was not the mode his primary was driving, and the second mode covers that case.
The second objected to the word: "这样是测打火频率吧,并非固有频率吧", this measures the sparking frequency, not the natural frequency. That is the main argument here in nine characters, from someone looking at a photograph of a scope.
A third, eight days later, put the correction in the form worked through above: the measurement gives the coil's own resonant frequency, and 实际频率要大于这个测试频率才真的谐振, the actual frequency has to be higher than the measured one for the system to be truly resonant. That is the upper pole, described by someone who does not use the word.
All four are right about something. A floating probe does hear the resonator. What it hears is the resonator as the machine is currently running it, which is a pole and not the winding's own number, and the gap between those two is what all of the above is about. The thread never resolves, which is how this argument usually ends wherever it comes up.
The frequency falls, the pole does not change
The arc adds capacitance and pulls the secondary's frequency down, and both poles come down with it. It stays the same mode. You stay on whichever pole you landed on at the start, for the whole bang.
Until they stop existing
A pair of resonances that can be moved can also be destroyed, and the condition for it is exact. Udo Lenz, on the Tesla Coil Mailing List in February 2013:
system loading makes the center frequency and one pole go away, leaving only one frequency near the primary resonance… That will happen when Qsec drops below 1/k.
The frequency left is near the primary's resonance, not the secondary's. We had that backwards until the source turned up. It has to be that way round: the condition is written on the secondary's Q, so the secondary is the resonator being damped out, and a frequency cannot be set by the resonator that was just killed.
Sweep the coil with no arc out and there are two sharp peaks, one at 317 kHz and one at 519, with a dip between them. Now load it. The load uses up the secondary's Q: 199 with nothing drawn, and 7.6 with a metre and a half out, which is 1/199 + Z/R_arc on this coil's 26.6 kΩ against the arc's 210 [derived]. The 4 often quoted beside that figure belongs to Hydron's coil, whose impedance is nearer 51 kΩ; it is the arc's resistance divided by whichever impedance you hang it on. As Q falls, both peaks get broader and lower and slide towards each other. The dip fills in. Past Q = 2.375 there is no dip left and no two peaks, just one broad hump near 349.9 kHz, which is the primary.
The secondary stops being a resonator. The primary never stopped being one, and what is left is the primary's own resonance with a lossy load hung on it.
This explains a piece of QCW practice that otherwise looks like superstition. A DRSSTC runs k around 0.15, and 1/0.15 is 6.67. At a loaded Q of 4, which is what a DRSSTC of that impedance runs, that coil is already past the condition with a margin of 0.6, and at k = 0.25 it is exactly 1.00, on the line. Our own coil should be read at 7.6 rather than 4, so at 0.421 the margin is 3.20 [derived], not the 1.68 printed here before, which paired our coupling with somebody else's loaded Q.
Tight coupling keeps the pole structure alive under load. The QCW habit of running k = 0.4 to 0.5 is therefore about more than the arc-to-secondary ratio. It also stops the two poles from merging as soon as the arc gets long. That last step is our inference; the condition and the numbers are Lenz's.
Two things follow that are easy to miss. The collapse arrives sooner than the arithmetic says: Lenz adds that a large split between the primary and secondary resonances brings it on earlier, and this coil's split is 21.9 per cent measured against the primary, so any arc length computed from Qsec < 1/k alone is a ceiling rather than an estimate. Past that point there is no pole to choose: "for large system loads, you'll have just one ZCS frequency, so there is no choice between poles at this point." Everything above about choosing a pole applies to the start and the middle of a bang.
An arc reaching an earthed object does the same thing, but only across a band of strike resistances, and it does three other things besides. That is its own event, separate from the behaviour of coupled resonators.
The lock points go before the poles do
A sweep sees the pair of peaks. The driver sees something narrower: the frequencies where the primary current's phase crosses zero, which are the ones it can lock to. A coupled pair has three of those, the same three the sweep shows as two dips and the peak between them, but the driver behaves differently at each.
Every figure in this section is on the kechuang model whose component values are given further down, with both circuits near 205 kHz, and not on the 349.9 against 426.5 used elsewhere. It is the machine the widget below is built from, and what matters here is the shape of the curves.
k = 0.3, no arc, both circuits near 205 kHz
180.5 kHz    62.7 A    phase slope -21.97 °/kHz    holds
204.9 kHz     2.1 A    phase slope +11.31 °/kHz    repels
245.1 kHz   114.0 A    phase slope -21.81 °/kHz    holds
The phase crosses zero at all three, but a lock is only stable where it crosses going down, from above. Where it crosses going up, the smallest drift is amplified and the driver is thrown off. The middle frequency is therefore the boundary between the two basins rather than a lock point, and it is the secondary's own resonance: tuned from 0.80 to 1.10 of nominal, the two outer points move but the watershed stays at 204 to 206 kHz.
The middle can also do damage. On the build in HVF 3057, with a lower pole around 75 to 81 kHz and an upper around 115 to 121, the space between them holds an antiresonance, a zero near 100 kHz, and the transitions across it drew a surge of about 135 A. A driver that hunts, or a tuning that lets the operating point wander over the middle, is briefly exposed to a current excursion as well as running inefficiently. That machine is continuous-wave, which is already outside the rest of this subject, so we do not know whether the surge scales down.
The 0.8 on that page is not the coupling those poles belong to, and the arithmetic said so before the schematic did. The pair sits 1.42 to 1.61 apart, which the pole equation puts at k = 0.34 to 0.45, where 0.8 would put them a factor of three apart [derived]. davekni's own line resolves it: "L1 and L2 with 0.8 coupling are the 5-turn DRSSTC primary coil", and L3 is the secondary. The 0.8 is between the two halves of a centre-tapped primary, not between primary and secondary, so nothing is misread and the pole pair stands.
Then grow the arc:
Rload     lower           boundary        upper
1000k    180.5 / 62.7 A   204.9 / 2.1 A   245.1 / 114.0 A
 500k    170.3 / 12.3     176.7 / 5.2     232.9 / 155.7
 300k    one lock point                   229.9 / 134.5
The lower point weakens and slides up into the boundary, and at a few hundred kΩ of load the two meet and annihilate. Below that a single lock point is left, the upper one, and there is no choice to make.
That is a second threshold, separate from the pole collapse. The lock points go well before the peaks merge:
k      lock points gone   gain peaks merged   ratio
0.3        458 kΩ              126 kΩ            3.6×
0.6        213                  62               3.4×
The driver loses the lower option about three times earlier in arc resistance, and so noticeably earlier in arc length, than a sweep loses the lower peak. A coil can be firmly on the upper pole with the lower one still plainly there on a sweep.
Below a coupling of 0.0595 the third frequency never exists and the lock is unambiguous from the first cycle. Every practical QCW runs well above that, so the pole is a real choice and the driver has to be told which to take.
In ohms, the condition is on resistance, not capacitance
Qsec < 1/k is written on the secondary's Q, but that Q is really the arc's loading, and putting it in ohms shows which term sets the collapse. The arc hangs on the topload as a parallel resistance. Referred into the tank it damps the secondary, so Qsec ≈ R_arc / Z, where Z = √(L/C) is the secondary's characteristic impedance, 26.6 kΩ here. The condition becomes
Qsec < 1/k ⇔ R_arc < Z/k = 63.2 kΩThe poles come apart when the arc becomes more conductive than that, and there is no capacitance in it at all. Everything here about the collapse, the Q under arc and the ringdown rests on the arc's resistance, the less well known half of the arc.
It is less well known than it needs to be, partly because the figures come in two forms. Half the published figures are quoted as a series R-C where the criterion wants the parallel one, and compared as written they spread by 28× and flip the verdict. Reduced to the same form and to a 1.5 m arc on this coil (R ∝ 1/L):
source                      as quoted   R∥ kΩ   margin
Anders, 8 pF/m ∥ 75 kΩ·m    parallel       50   0.79×
Uspring, 47°                parallel       77   1.22×
Weston, 210 kΩ·ft           series         79   1.26×
Uspring, 55°                parallel      103   1.63×
Anders, 16 pF + 8 kΩ        series        225   3.56×
textbook, 220 kΩ + 1 pF/ft  series        258   4.08×
Five of the six put the poles alive at 1.5 m. Their margins run 1.22 to 4.08×, and our own figure sits inside them: the 210 kΩ we use for a metre and a half of arc is 3.32× on the same form, R∥ over Z/k [derived, 210 / 63.2]. Across those five, the conversion leaves the resistances spanning 3.3×, not the 28× the raw quotes suggest.
The top row is the exception, and it is the newest. Anders Mikkelsen revised his own series figure, the other row carrying his name, on the grounds that "a parallel one is more representative", and published 8 pF per meter in parallel with 75 kohm*meter fitted to his measured 50 degrees near 340 kHz and 60 near 460 (HVF 3140). The constant reproduces both angles: 1.5 m of it is 12 pF and 50 kΩ, whose reactance is 39.0 and 28.8 kΩ at those two frequencies, so arctan(R/X_C) is 52 and 60 degrees [derived]. It is the only row of the six fitted to measured phase at two frequencies in the parallel form the criterion needs, and it lands below Z/k. On that figure an ordinary metre-and-a-half arc takes this coil's poles apart by itself. Including it the six span 5.2× [derived, 258 over 50], and the verdict on the collapse is five to one rather than unanimous. The same builder is in the table twice, on either side of the answer. That is where the question stands, and it is no reason to drop either row.
That 3.32 and the 3.20 earlier are one margin counted two ways. The rows above use the arc alone, R∥ over Z/k. The 3.20 adds the winding's own 199, so Qsec is 7.59 rather than 7.90 and the product with k comes down four per cent. Neither is the 1.68 printed here before. That one paired our coupling with the loaded Q of 4 Uspring measured on Hydron's coil, whose impedance is near twice ours, and it is withdrawn here as it is on the coupling page.
Two of these rows disagree with themselves, so they are left out of the spread:
- The textbook "220 kΩ + 1 pF/ft", in parallel form, implies 0.48 pF/m of arc capacitance, a tenth of every measurement. It was written for a spark gap and does not carry over to a QCW streamer.
- Anders' "16 pF + 8 kΩ" implies a voltage-to-current angle of 74°, well outside every other row here. His capacitance is corroborated by the detuning, so the resistance is the suspect term: 52° at 16 pF wants 22 kΩ in series, not 8.
An earlier version described the band Anders sits outside as "the measured band is 45 to 60", and neither end is a measurement. They are the 47° and 55° rows of the table above, both Uspring's, one man's two figures rounded outward. A measurement does exist, and it is somebody else's. davekni reads the angle off an instrument and states it from the capacitive end rather than the resistive one, the complement of the convention used here: 40 to 45 degrees is the common case on his coil, and one arc came in under 30. Converted, that is 45 to 50 in our terms with the outlier past 60 [derived, the conventions are complements], so the band barely moves and now has an instrument reading inside it. At 45 the two conventions meet, which is where the arc's resistance equals its reactance, and Steve Conner's hungry streamer lands there too, from a model rather than a probe.
The lesson for measurement is to read the angle between the arc's voltage and current, not R and C separately. The angle does not care whether the model is written series or parallel, and the pair falls out of it. It is the same way around the capacitance model as the frequency-tracking test below.
And the threshold itself checks out on someone else's coil
Every row above is a published arc resistance tested against the threshold. None of them tests the threshold itself. R_arc < Z/k is our own reduction, and it had not yet been checked against a coil solved independently of our figures.
A model published on the Chinese forum kechuang provides that check, using neither our circuit nor our arithmetic on the loading. Its arc capacitance grows with the load, so Z moves as the arc does and the collapse point has to be solved self-consistently. Here is our R_arc < Z/k against that solution, at their component values, across coupling:
k      our Z/k      on their model     discrepancy
0.3    123.6 kΩ     125.8 kΩ           -1.8 %
0.4    92.1         95.9               -4.0 %
0.6    61.0         61.6               -1.0 %
They agree to one to four per cent from k of 0.3 up. This is the first check of the collapse criterion itself, as distinct from the pole frequencies it acts on, which the measured coils earlier already confirm. Those are two different claims: that the poles sit where the equation puts them, and that they come apart where R_arc crosses Z/k. This check covers only the second.
The values, so it can be repeated: secondary 35.4 mH and 17 to 26 pF, primary 60 µH and 10 nF, k from 0.2 to 0.6.
This also clears up an apparent contradiction. Their collapse resistance is about 126 kΩ and ours is the 63.2 kΩ above, and the difference is all in the machine. Their Z is around 37 to 46 kΩ against 26.6 here, and Z/k carries the rest, 123.6 against 63.2, a factor of 1.96 against the 1.99 between the two solved collapse resistances [derived].
The 11.2 to 39.6 kΩ band that a ground strike carries is a different quantity and does not belong in this comparison. It is the range of strike resistances over which a lumped model makes the structure come apart, and it has a bottom edge because a low enough channel stops damping and starts shorting. Z/k has no bottom edge.
And past it is a place you can work, not a place you have failed
Running past the collapse is a regime you can work in, and earlier versions were wrong to imply otherwise. Anders Mikkelsen took 3.18 m operating beyond the collapse, and describes the regime without apologising for it: only one ZVS frequency, and arc loading with minimal effect on the operating frequency.
That last clause is the diagnostic, and it beats any threshold calculation because it needs no capacitance model:
poles alive
  frequency tracks the arc

past collapse
  frequency stops caring
A machine whose frequency stops responding to arc length has not drifted. It has left the two-pole regime, and from that moment the arguments about choosing a pole no longer apply.
The one remaining frequency sits near the primary's resonance, about 349.9 kHz here, as Lenz states in the sentence that gives the collapse condition. It is also close to where this coil already sits, 349.9 against a loaded secondary near 355 at a metre and a half, because the primary is tuned onto the loaded secondary rather than the unloaded one. A coil tuned the other way, which is the more common habit, does not get that coincidence, and for it the collapse is a jump rather than a small step. A first capture past collapse will not end any dispute, but it will pin the number this coil actually lands on.
The argument nobody should flatten
Uspring's position is that on the lower pole the arc pulls the secondary towards the working frequency and the transfer improves, while on the upper it pulls away and the coil detunes. davekni's is that the upper pole gives 12 dB of arc power at one simulated load. Both observations are real, and neither cancels the other.
In practice builders compromise: tune the primary below the secondary, and force the upper pole from the driver. The arc then brings the frequencies together as the ramp goes on instead of separating them. davekni puts it as being able to force upper pole operation even with the primary tuned lower, so that arc loading lowers the secondary resonance and keeps the frequencies close over the whole of the arc's growth.
Getting the inputs without trusting a model
Every number here comes from k and the primary's resonance, and both are usually taken from a simulator. One sweep of the cold coil measures them instead, with nothing running.
The other bench route to k is to read the primary's inductance with the secondary open and then shorted. That assumes the shorted winding behaves as a short circuit at your working frequency, and at QCW frequencies the assumption breaks down. The sweep does not depend on it.
It takes three readings, not two, for a reason. The symmetric form that recovers k from the pole pair alone is quoted in the literature with its condition attached: it holds between identical resonators. A coil's two are not identical, so it fails here. On loneoceans' turn-10 pole pair, 255 and 362 kHz measured with the secondary grounded, it returns 0.337 where he states 0.306. We threw the formula out for disagreeing with his numbers before noticing it had been used outside the domain it declares. The two figures are not the same kind of thing either. His 0.306 is, in his own word, calculated, from the geometry of the system, while the 0.337 comes from frequencies he measured. They are ten per cent apart, on one coil at one tap. His ungrounded pair at the same tap, 282 and 394, gives a third answer, 0.323 [derived].
The method also gives you a consistency test. One sweep is not its own check, since the peak is the secondary's frequency and the two dips then fix k and the primary, with nothing left over. The check is to repeat it: measure several configurations, and the recovered k has to move the way you moved the geometry rather than wander.
Applied to Anders' published triplets, it wanders: three of his pairs return k of 0.263, 0.421 and 0.623, which is not one coil with one coupling. Something in that set is mislabelled. The same test will catch that on your own bench, and a number that fails its own closure check should not be quoted as a measurement by anyone, including us.
Checking which one you are on
Look at the frequency at the very start of the arc, at minimum load. It tells you straight away.
A sharp jump of about a factor of two in the middle of a ramp might be a real transition. A smooth slide downwards is normal.
The two poles are why a QCW's timing has to be tracked the whole way up the ramp, and why the department diagram draws a driver with a lead in it rather than a box marked driver.